
Build the device your program needs.
For qualifying programs, we can structure custom hardware and configuration-specific exclusivity.
Design a custom device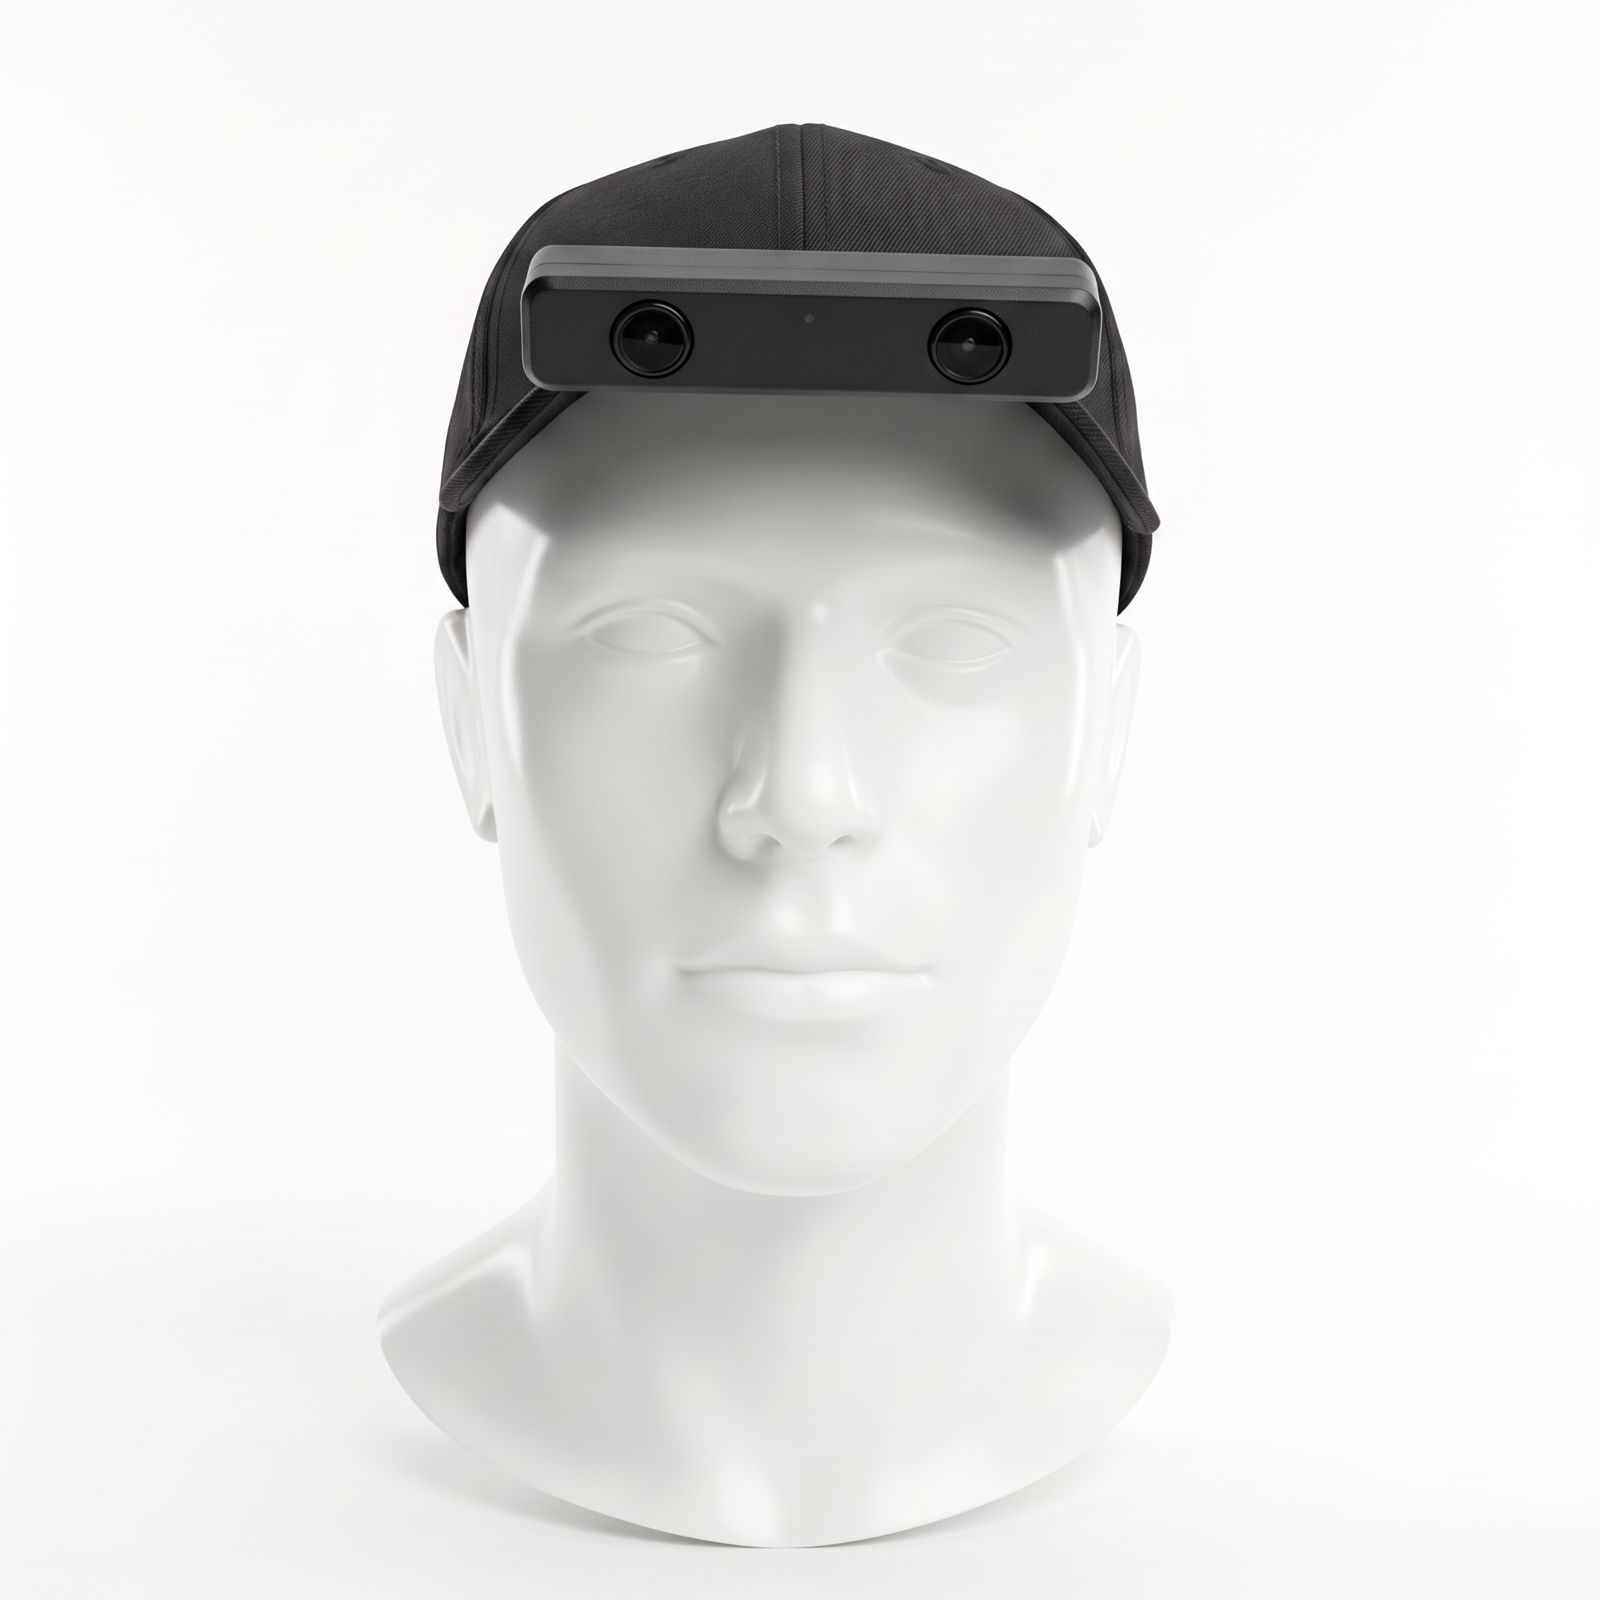
The lineup
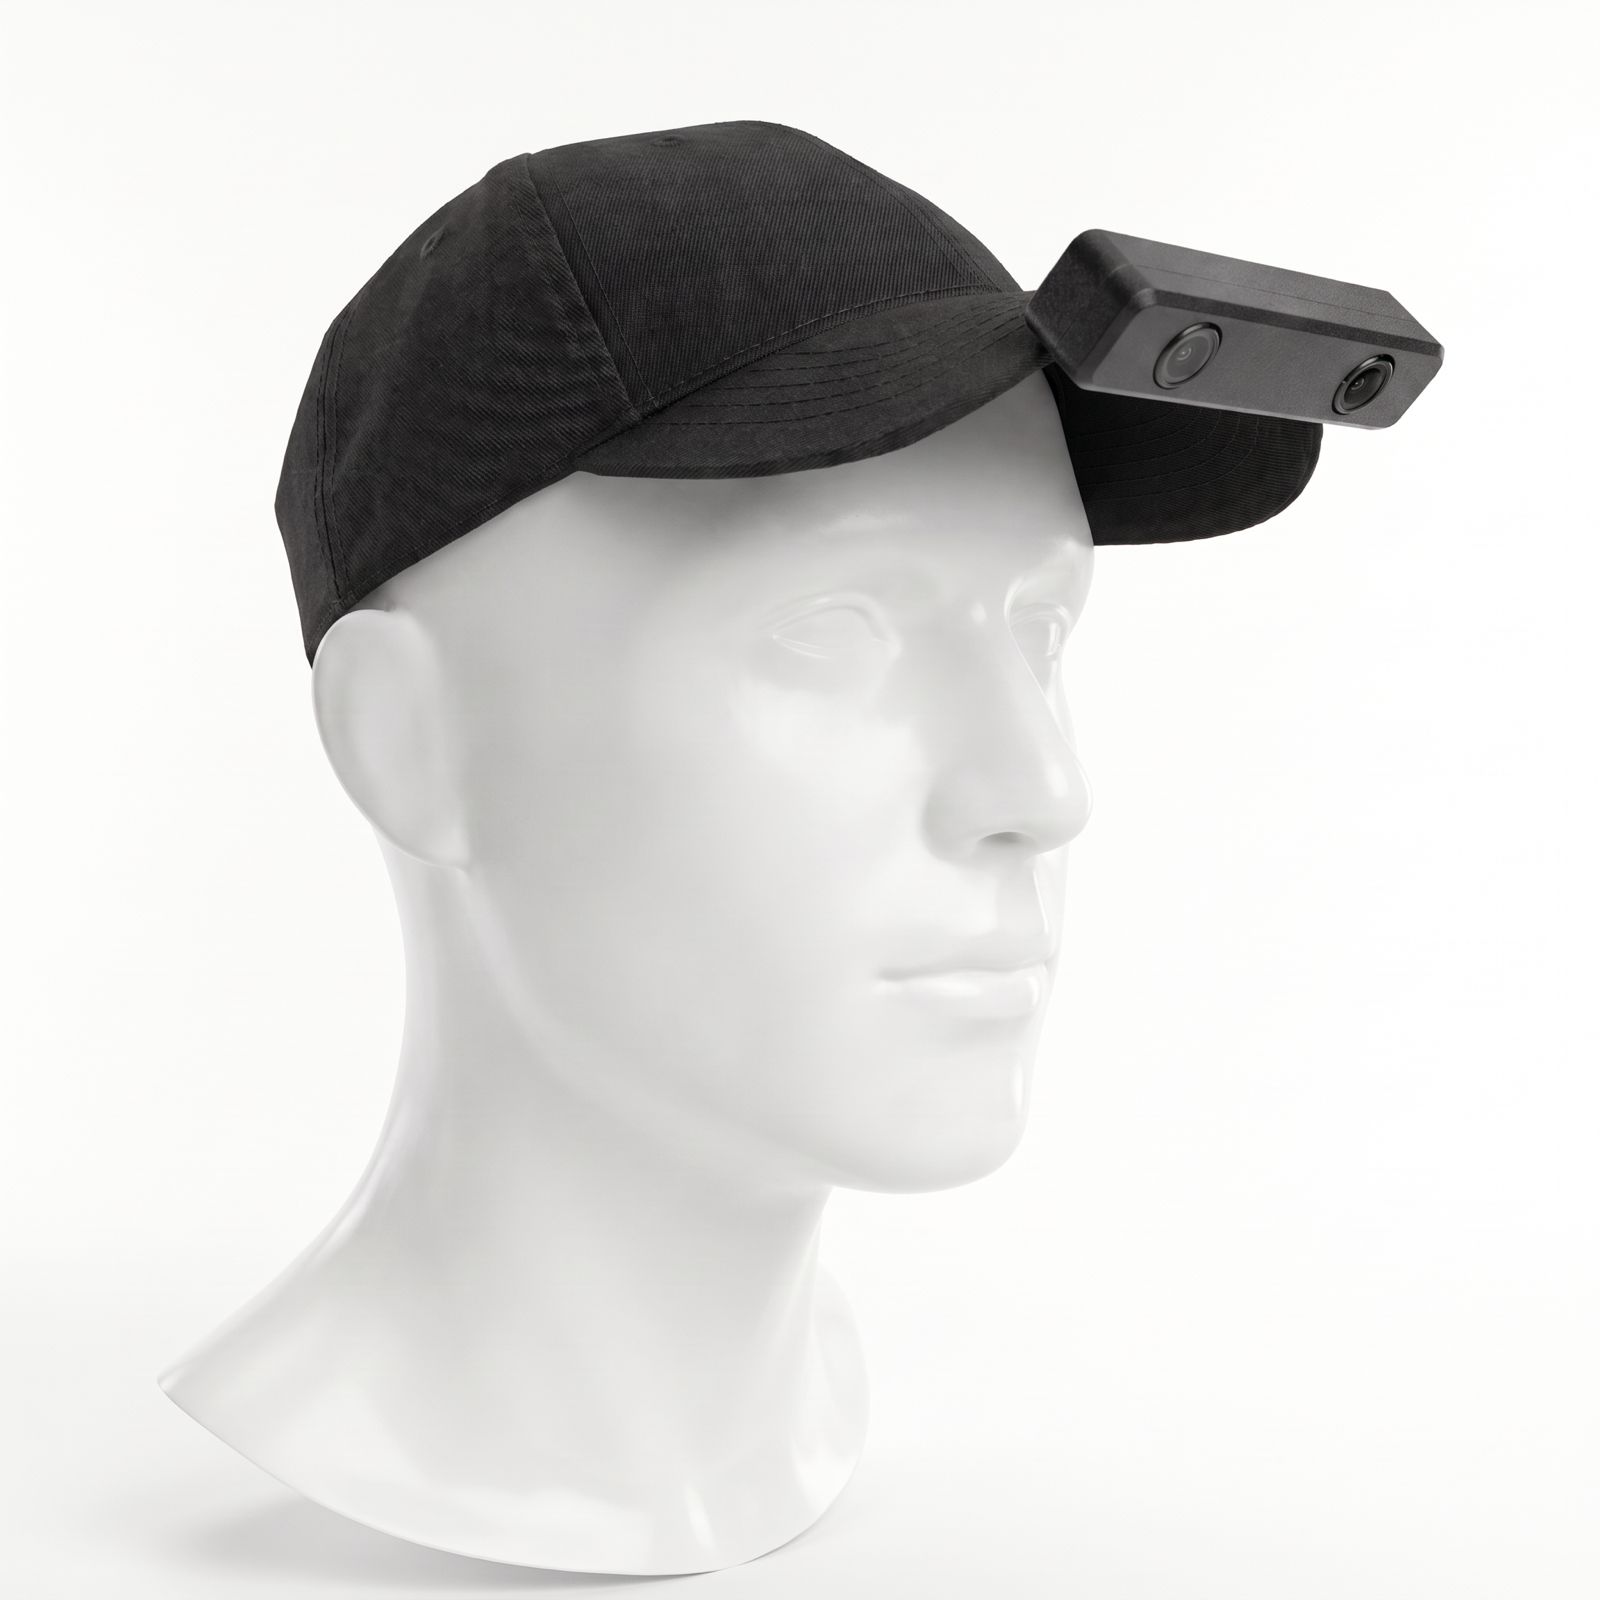
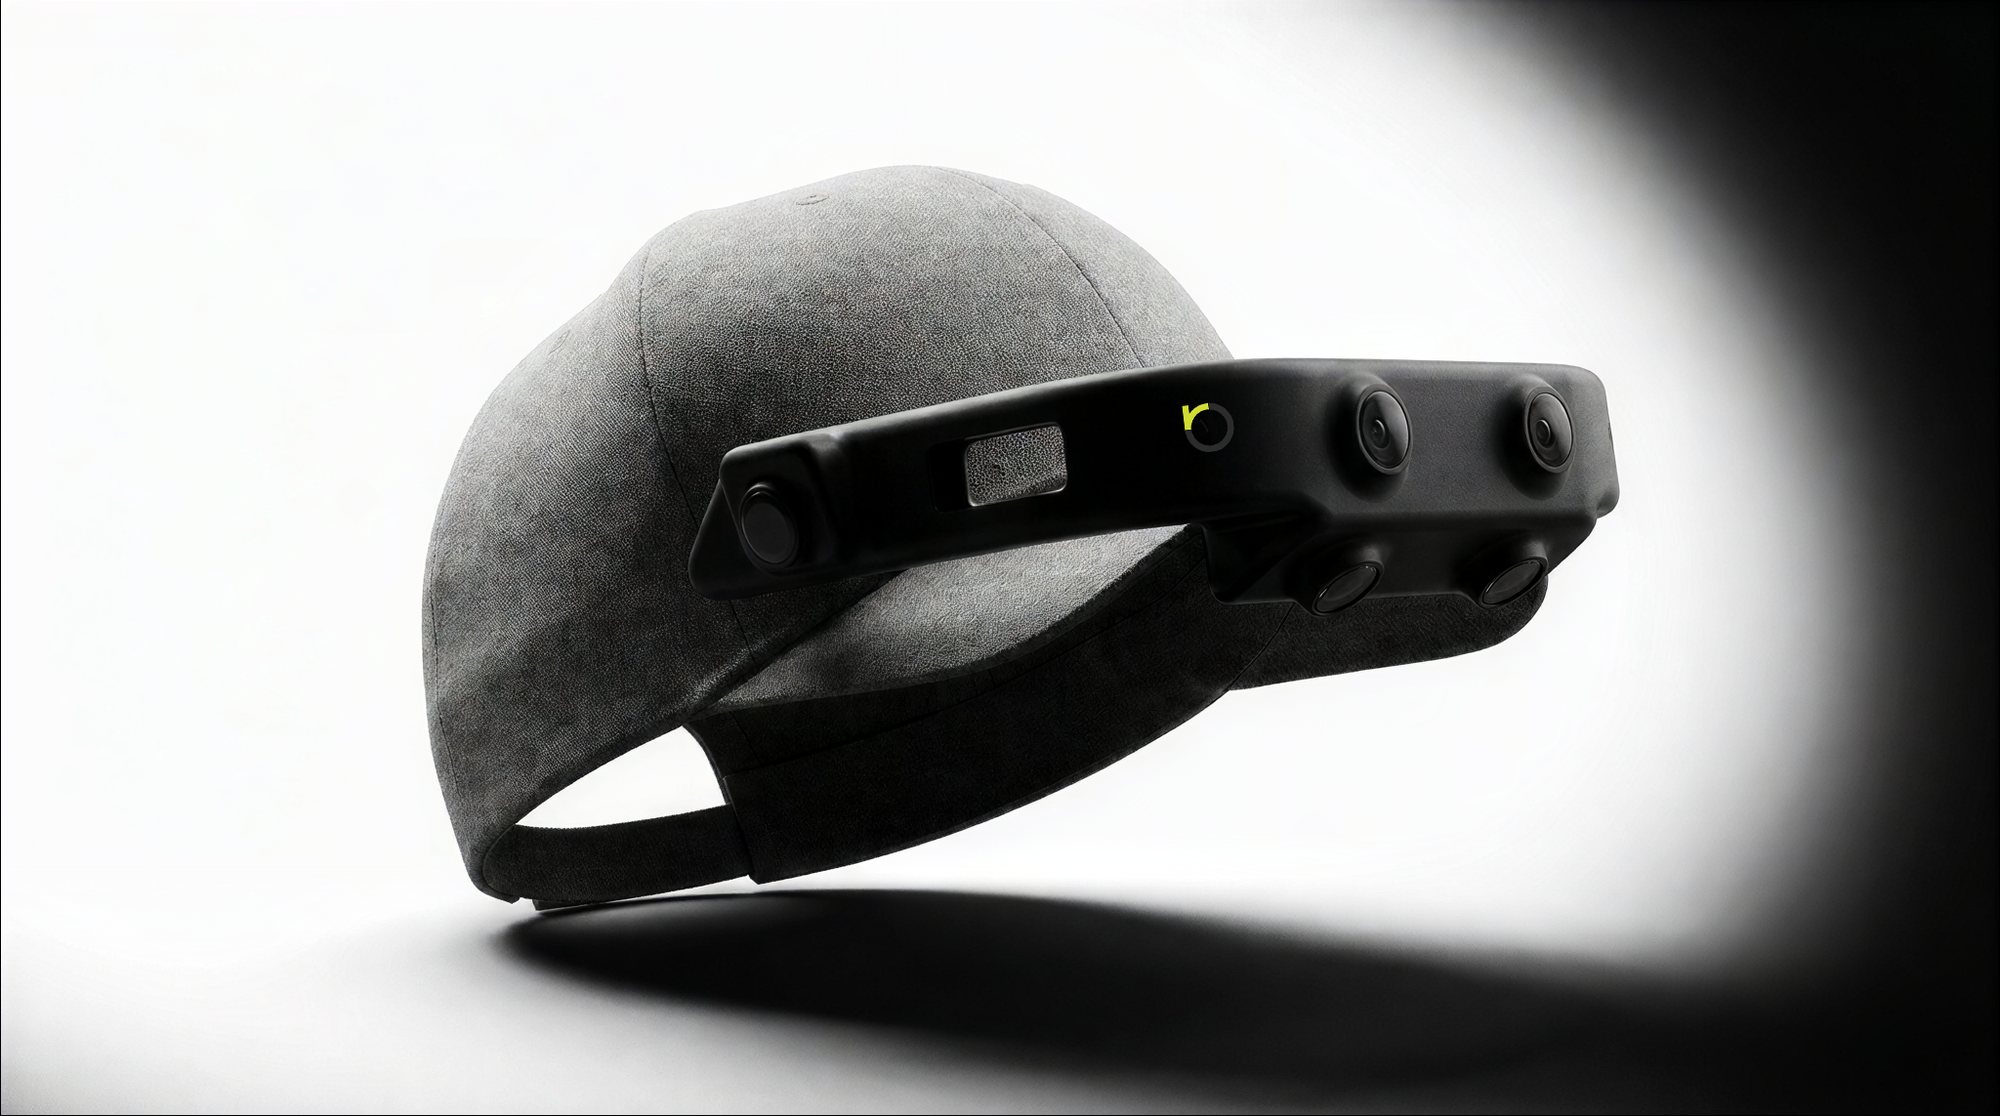
The head view holds the scene. The wrist views hold hand–object contact. The Six-camera cap adds downward and side views on the cap itself. Every camera on a rig shares one trigger, so every observation in an episode is from the same timestep.
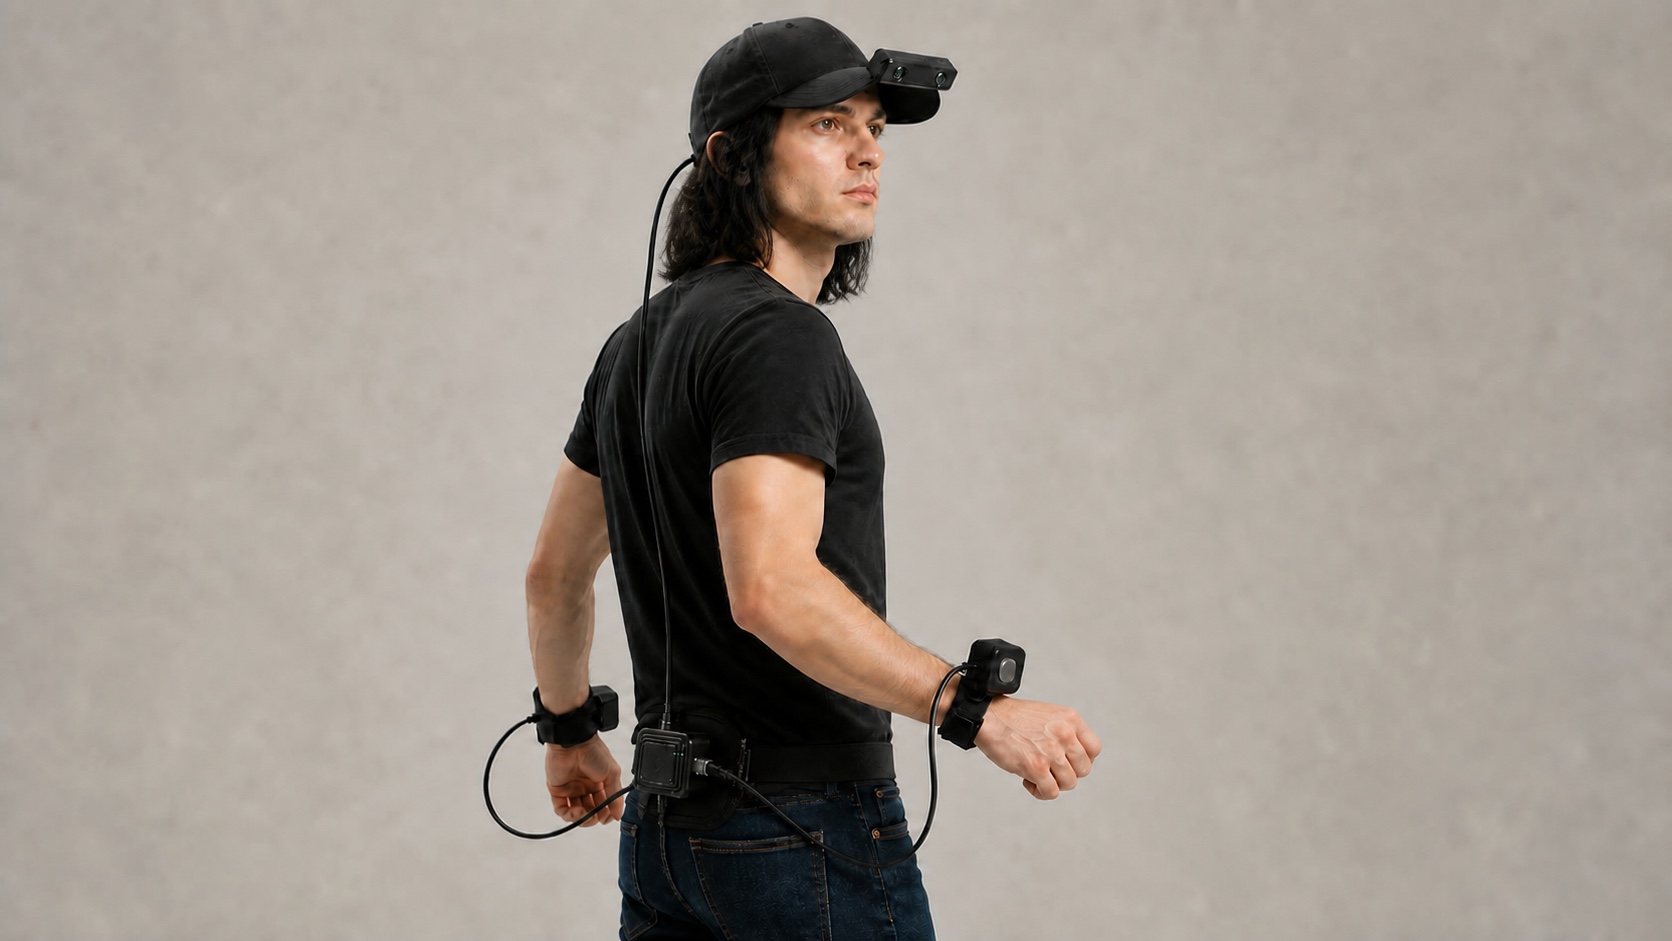
Select a camera to open its spec
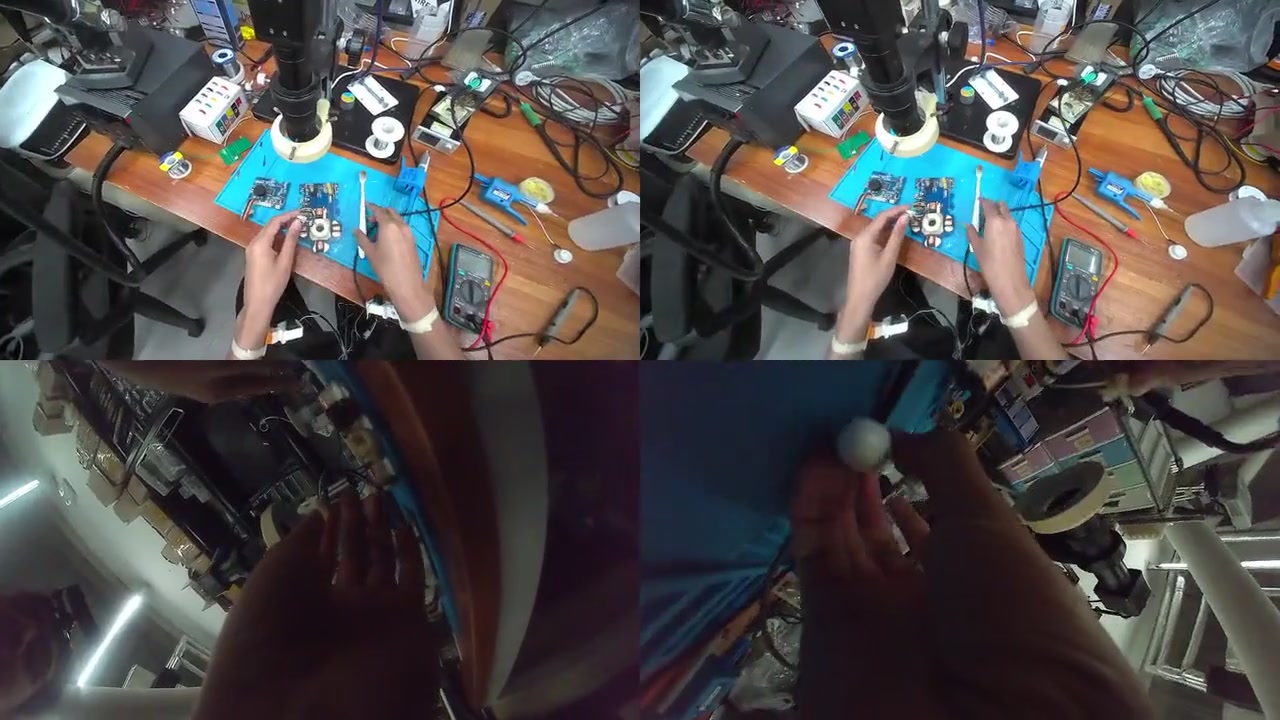 Real episode · soldering
See what the rig sees.
Left eye, right eye, left wrist, right wrist on one timeline. Hardware-triggered, no dropped frames, per-frame device timestamps.
Play the episode
Rotate the complete cap, inspect camera placement, and follow the cable route.
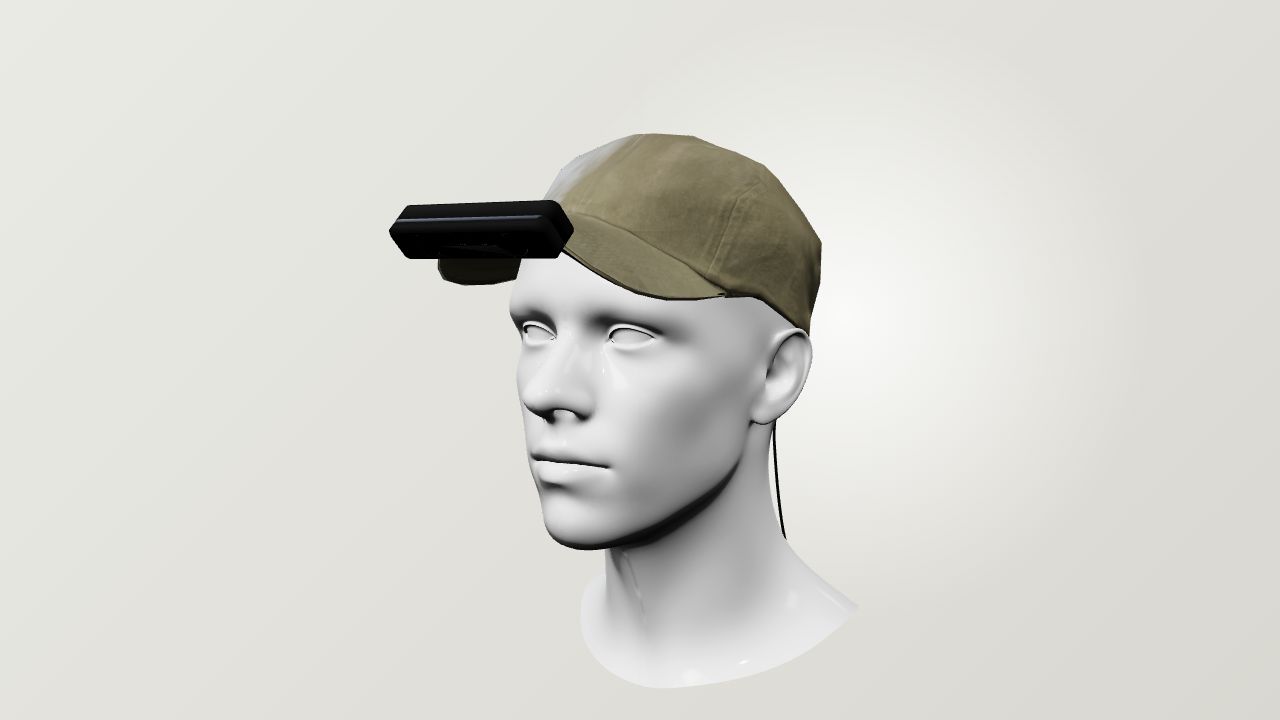
Interactive model
For qualifying programs, we can structure custom hardware and configuration-specific exclusivity.
Design a custom deviceWe turn task and modality requirements into collection hardware and a field data program.
Plan a data programResearch & notes
The evolution
We start with the hardware that creates training data, then move the sensing stack onto robots.
Stereo-cap records egocentric stereo video and IMU for close-range manipulation.
Mono camera modules, the Full Rig, and the Six-camera cap ship as samples. Multi-camera rigs with wrist sync and touch come next.
Vision, motion, and tactile sensing become one system.
The sensory organs move from people to robots.